Hardware
From capture
to execution.
One gripper geometry connects handheld demonstrations with evaluation on a real robot.
Data Collection Gripper
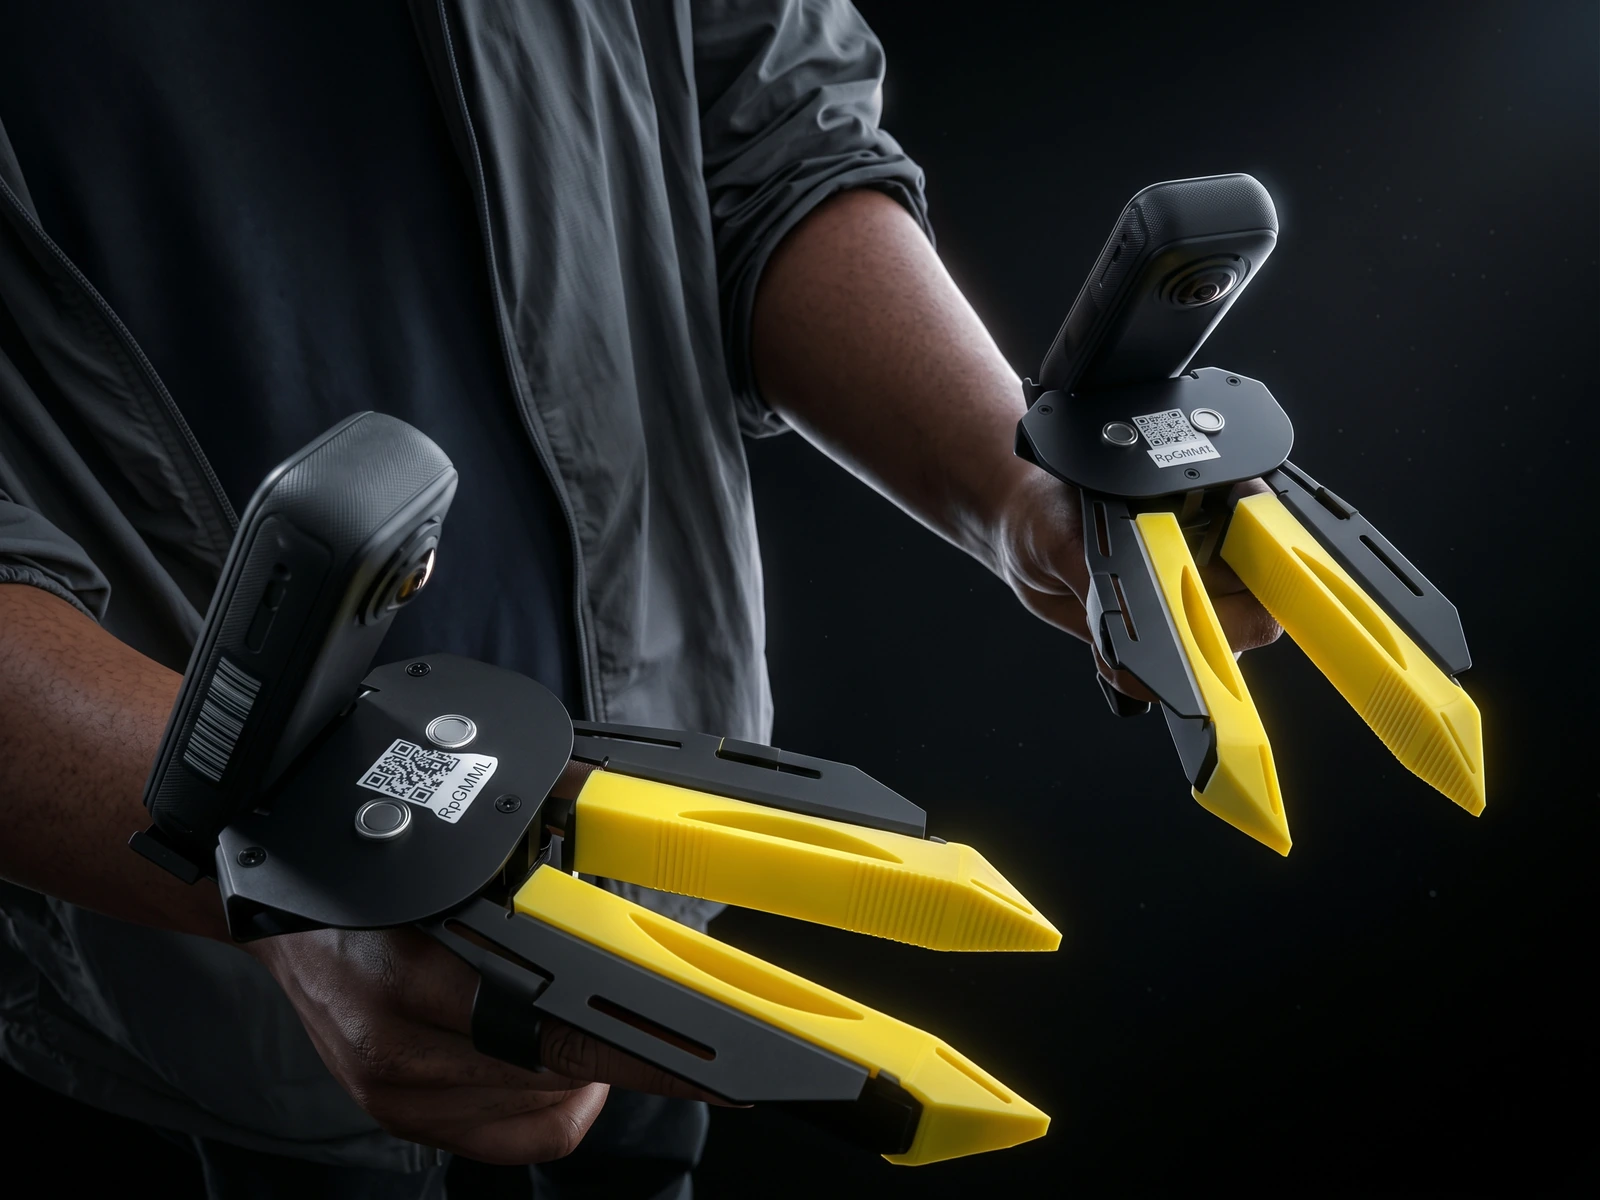
Demonstrate naturally. Record gripper motion, jaw action and the surrounding scene.
Bimanual data collection
A gripper in each hand captures two-handed demonstrations such as folding, lifting and repositioning objects.
Isomorphic Actuator
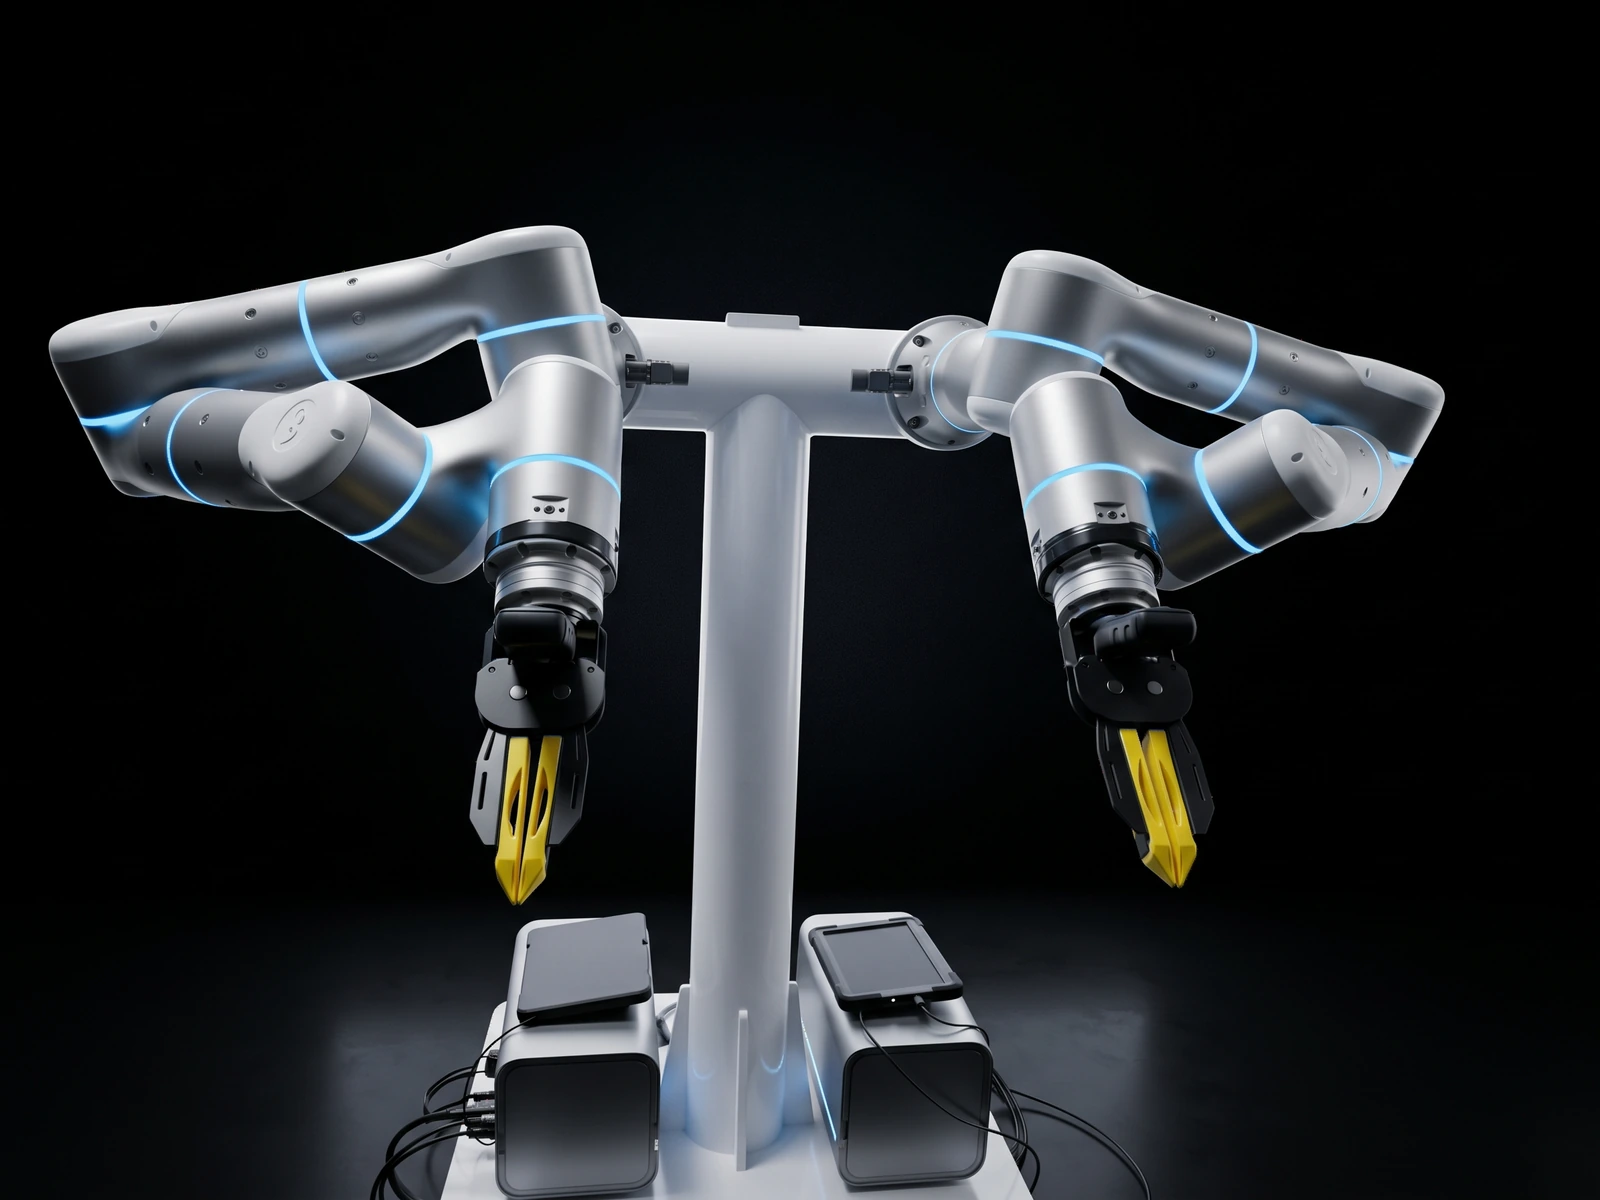
The matching gripper design on Flexiv and OpenArm setups, connecting demonstrations with robot execution.
Flexiv · Bimanual setup
A Flexiv dual-arm setup fitted with camera-equipped grippers for policy execution and evaluation.
More setups coming soon
Additional robot platforms and configurations are on the way.
Handheld rig specifications
Capture rig
- Weight
- 200 g
- Runtime
- unlimited
- Storage
- 1 TB
- Battery
- Swappable — change it mid-shift and keep going
- Handles
- A 1 mm sheet up to a 20 kg box, two-handed
- Coverage
- About 90% of everyday manipulation work
- Camera
- 2 × 360° body · 200° lenses, back to back
- Video
- 4K per lens, 50 fps
- Inertial
- 200 Hz, factory cam–IMU calibration on board
- Action
- Encoder-instrumented gripper, jaw angle logged
- Audio
- 48 kHz stereo
- Offload
- Portable SSD → hub, mirrored to object storage
- Fleet today
- 38 devices · 19 rigs